
How Do Microbots Work?

Microtumblers Use Friction to Grip a Surface and Move Forward. They Can Tumble off Ledges and into Valleys Several Times Their Size and Use Local Adhesive...
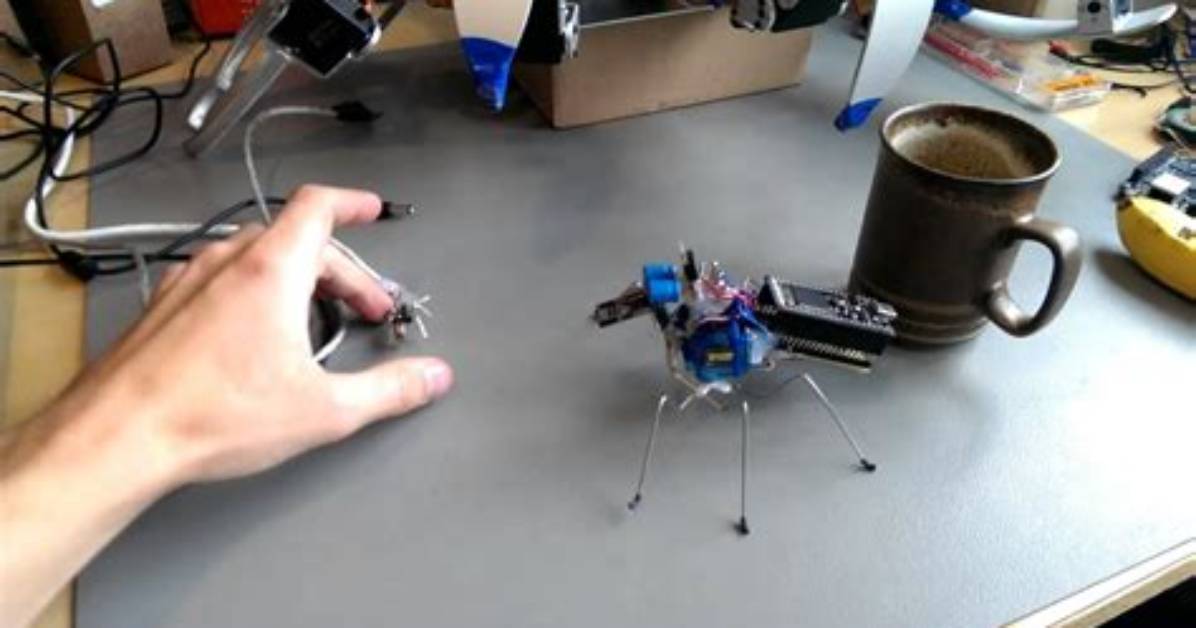
Microtumblers use friction to grip a surface and move forward. They can tumble off ledges and into valleys several times their size and use local adhesive forces to climb steep inclines. The small size of microrobots makes it difficult to generate real-time, noninvasive images of them inside the body.
How are Microbots controlled?
Researchers have developed a system for controlling the tiny robots with individual magnetic fields generated by an array of tiny planar coils. Microbots generally move in unison, but being able to control the movement of each robot independently opens the door to performing cooperative manipulation tasks.Is Microbots possible?
That's why I was pleasantly surprised to find that Microbots do in fact exists and its real! Not quite as sophisticated yet probably but already extremely helpful and effective. It's called Nanobots and its currently under testing in the medical field.
Maya is a hardware enthusiast who tests and reviews smart home devices, smartphones, wearables, and audio gear. She focuses on practical consumer value and build quality.
