
Move Linear Actuators Using softPWM Wiringpi

I Am Using softPWM from Wiringpi Library to Control Linear Actuator Speed and Direction. I Have Raspberrypi 4B Connected to Btn8982Ta Motor Driver Which Is...
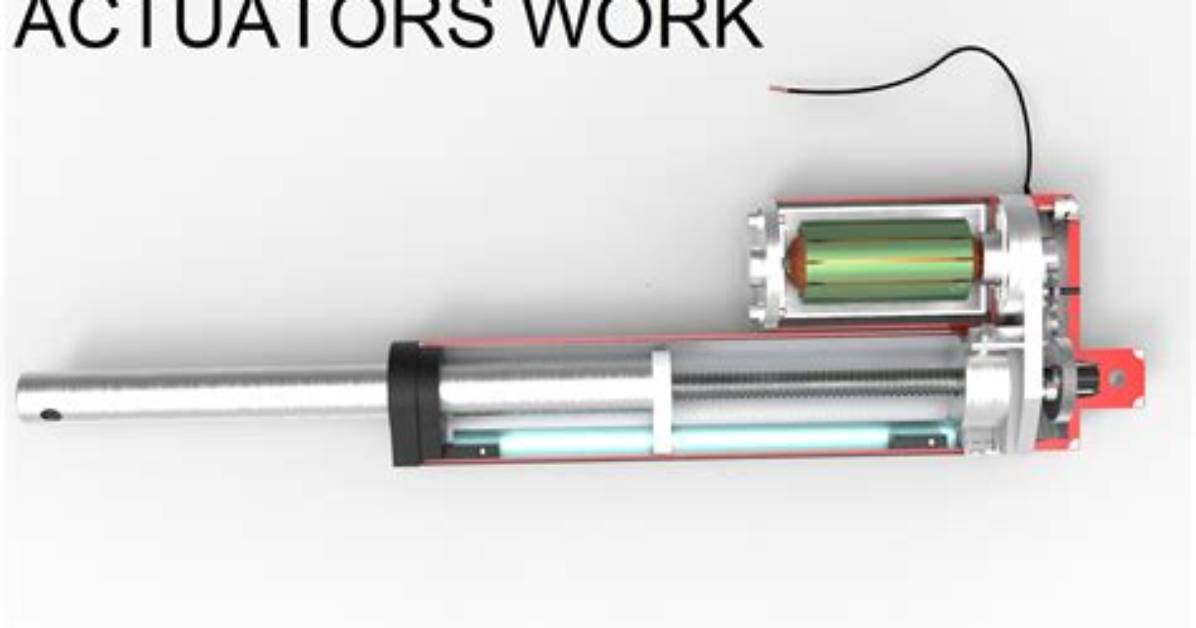
I am using softPWM from wiringpi library to control linear actuator speed and direction. I have raspberrypi 4b connected to BTN8982TA motor driver which is in-turn connected to linear actuator. I have created a python program to move forward and backward and 50% speed Program is as follows:
import wiringpi as s
from time import sleep
FPWM=0  #Pin No.11
RPWM=2  #Pin No.13
s.wiringPiSetup()
s.softPwmCreate(FPWM,0,100)
s.softPwmCreate(RPWM,0,100)

while True:
    s.softPwmWrite(FPWM,0)
    s.softPwmWrite(RPWM,50)
    sleep(2)
    s.softPwmWrite(FPWM,50)
    s.softPwmWrite(RPWM,0)
    sleep(2)
Actuator should retract for 2 sec and again go forward for 2 sec. But I am not able to achieve it, when I run the program, my actuator moves forward and forward till it reaches the limit, I want to know what I am doing wrong and how can I change the direction of the actuator
1 Answer
It looks like you might need to call the Wiring PI's sleep functions
Maya is a hardware enthusiast who tests and reviews smart home devices, smartphones, wearables, and audio gear. She focuses on practical consumer value and build quality.
